Computer science, University of Maryland, class of 2029.
Research apprentice, Army Research Laboratory, summer 2026.
Maryland's Mars rover team. I am building a controller that drives the rover's arm with a held iPhone instead of a gamepad, and I rebuilt the base station console the operators drive from.
The base station console
Five seats per mission, a readiness check, and one bitrate budget shared by every camera. Delivery mission shown; the driver and drone screens show the rover's own view.
An iPhone running Arm Pilot. ARKit tracks where it is and which way it points.
Same arm, four ways to track the operator
- PhoneARKit pose of a held iPhoneRecommended
- Stereo handTwo cameras, 21 landmarks, triangulatedWorks; depth noisy on fast motion
- Mono handOne camera, depth from apparent hand sizeWorks; depth as good as the size estimate
- Marker wandPrinted ArUco cube, gyro in the gripVerified in simulation; hardware being built
An open-source personal agent that runs on your own machine. It reads mail, calendar, messages, location and health into one ledger. Anything another person would see waits for a tap on your phone.
A drive-by-wire electric go-kart, pitched to replace the robotics curriculum at Poolesville High School and taught from as it was built.
Motor and controller
72 V, 40 hp peak
A FarDriver controller runs the motor, which turns the rear axle by chain. There is no friction brake. Braking is the motor, commanded in software.
Model built from photographs of the kart
- Motor and controller. 72 V, 40 hp peak. A FarDriver controller runs the motor, which turns the rear axle by chain. There is no friction brake. Braking is the motor, commanded in software.
- Cooling. Liquid loop above the motor. A radiator with two fans, a pump and a reservoir.
- Battery. 72 V pack under the floor. A JK BMS watches the cells and reports to the dashboard. Power reaches the controller through a main contactor that only the Teensy can close, and only once the kart is armed.
- Steer by wire. ESP32, Talon SRX, CIM motor. Nothing mechanical joins the steering wheel to the front wheels. An ESP32 runs a PID loop on a potentiometer and drives a CIM motor through a Talon SRX. The target angle arrives over CAN 50 times a second. If it stops for 150 ms, the motor is cut.
- Wheel and pedals. USB into the Teensy. A Hori racing wheel on the Teensy's USB host port. The wheel angle becomes the steering target and the pedals become throttle and brake. If its reports stop for 100 ms, the kart brings itself to a stop.
- Dashboard. React on a Raspberry Pi 4. The Pi runs the dashboard and only listens. It can crash without affecting the drive.
- Mainboard. Teensy 4.1 on a custom board. Behind the screen, one board joins every system. The Teensy is the only computer that can move the kart: it holds the drive state machine, the pedal mapping and the watchdogs. The wheel reaches it over USB on these traces, and its commands leave as I2C to the throttle DAC and CAN through an MCP2562.
- Drive by wire. Every signal on the kart. Commands leave the Teensy, telemetry comes back to it, and the Pi sees a copy.
Llama 3.1 fine-tuned on five years of my own text messages. My best friend could not reliably tell it from me.
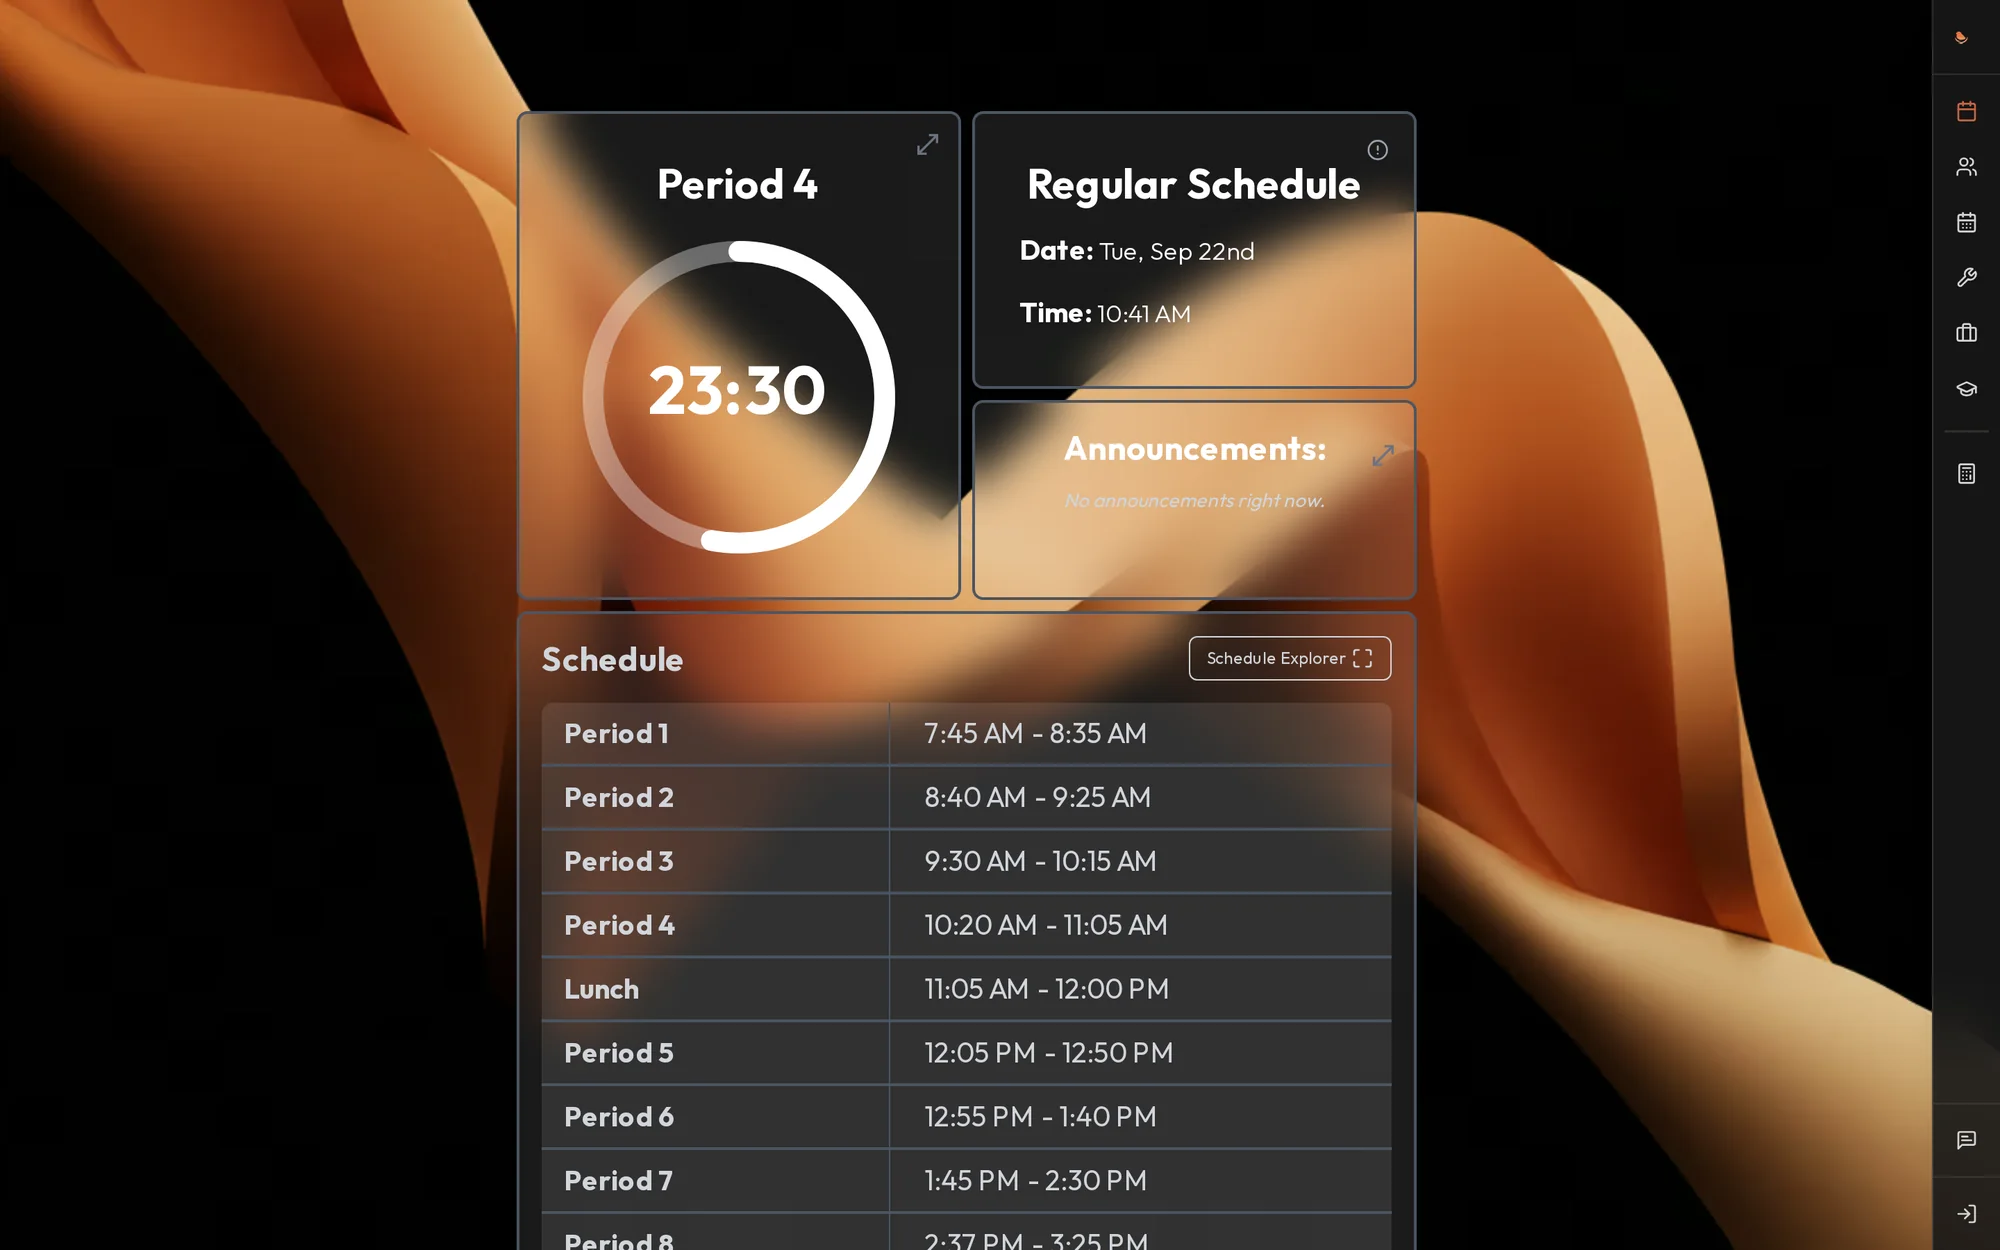
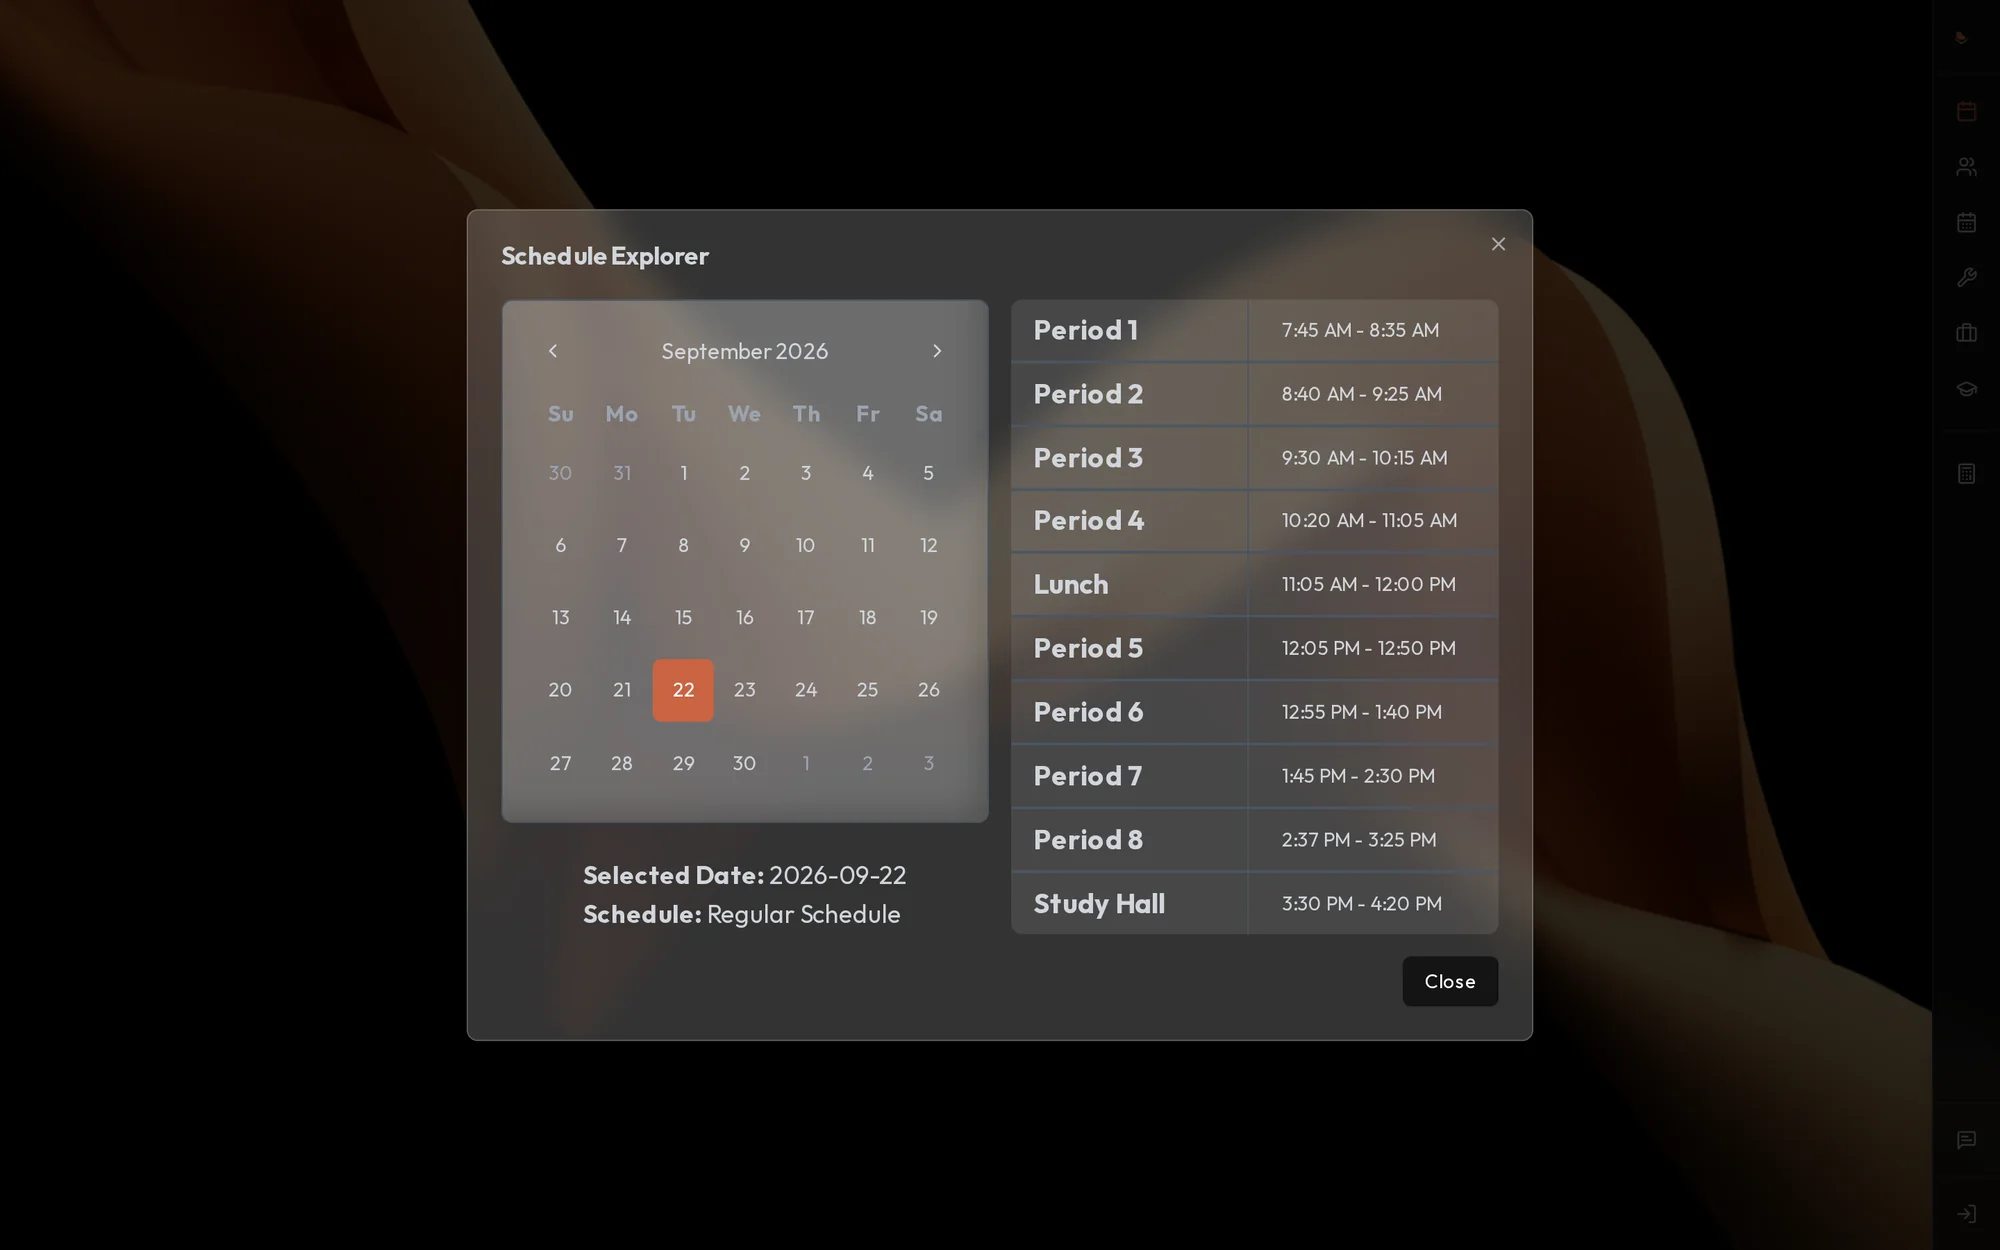
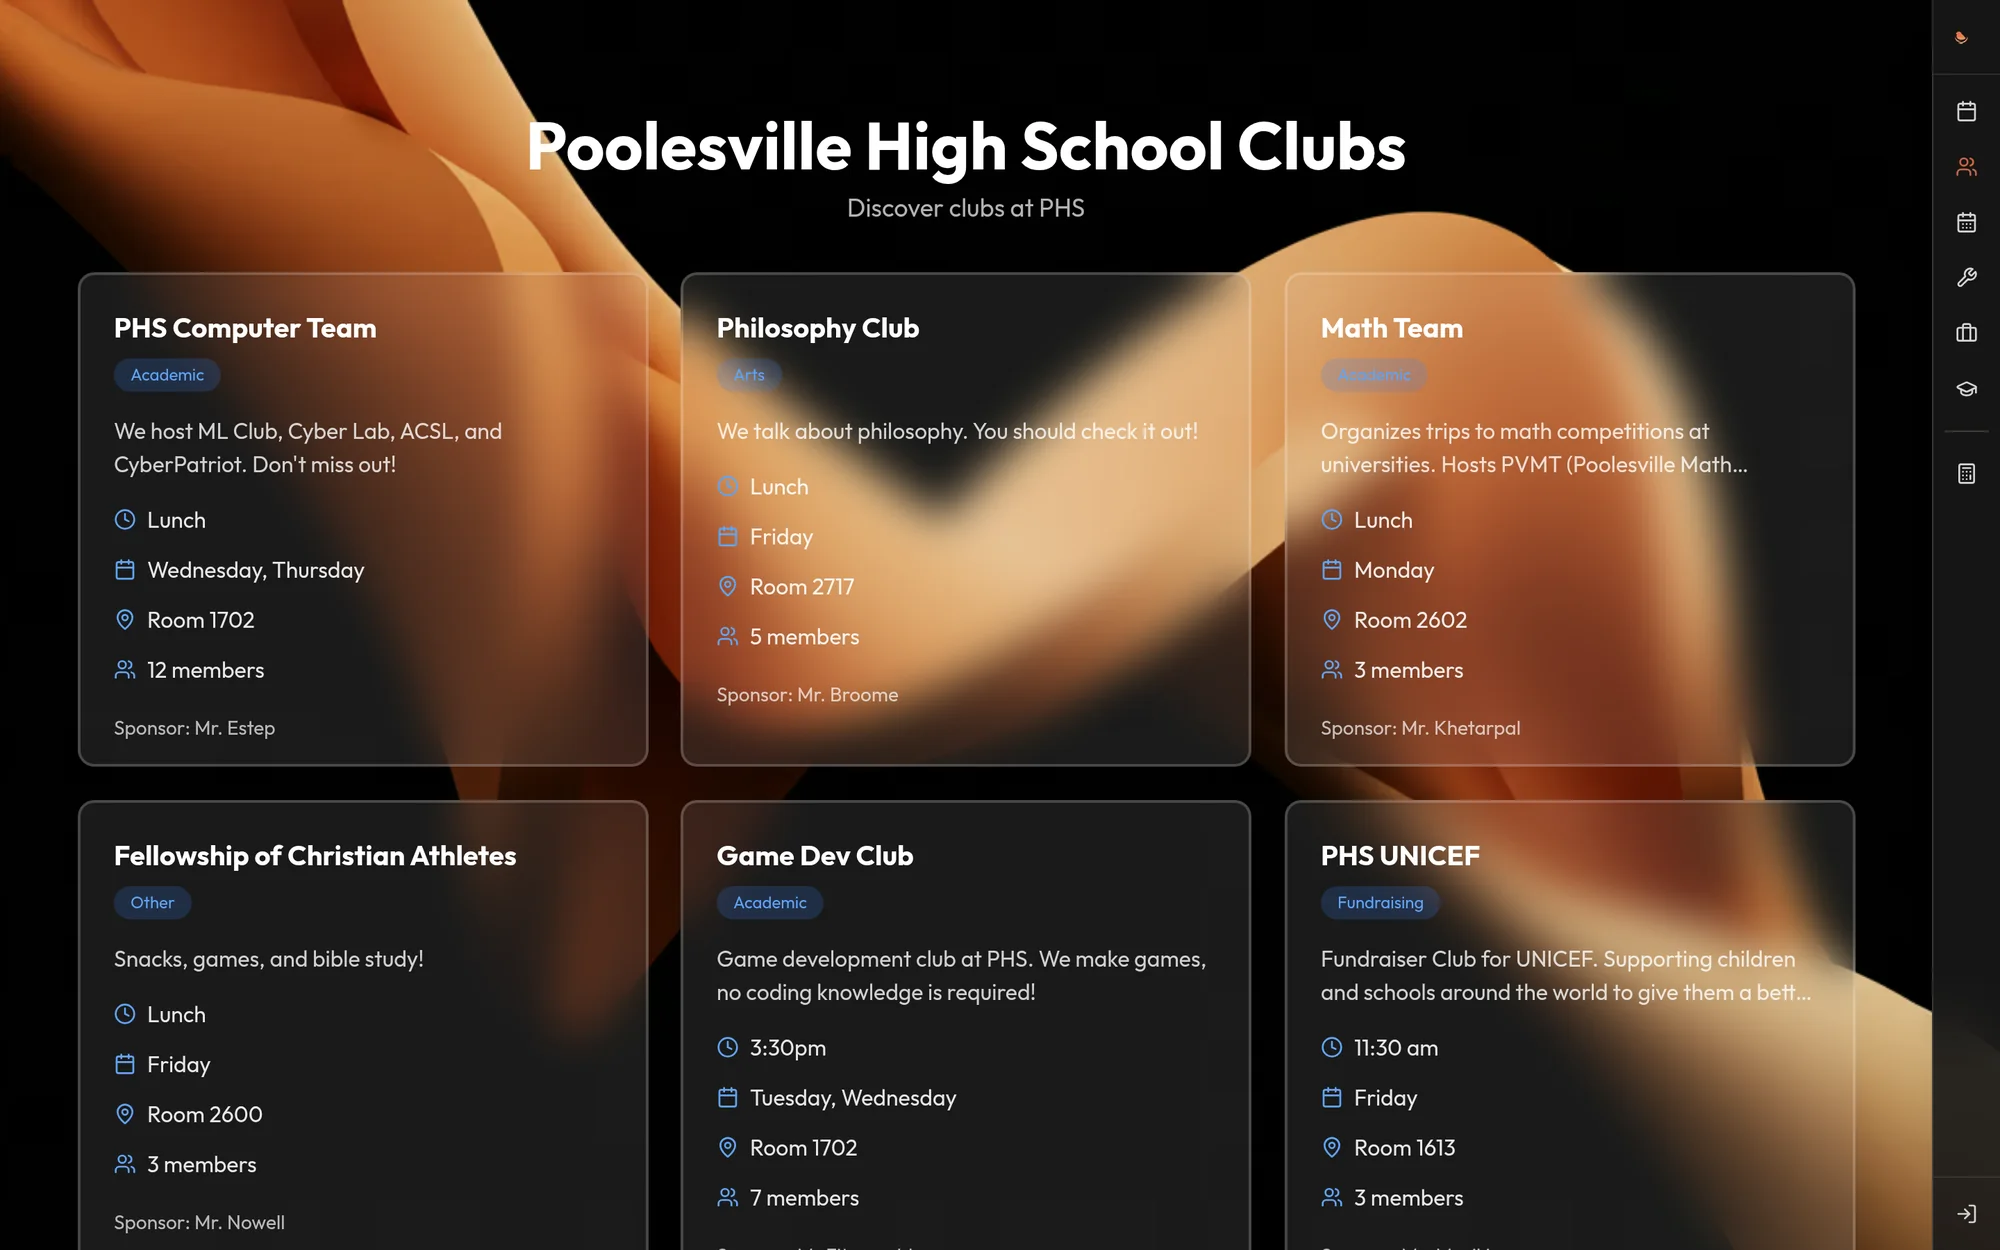
A dashboard for every school in the county: schedules, clubs and announcements, in English and Spanish. It ran on every classroom TV at Poolesville. Handed off in 2026.
Finding where GPS is being spoofed, using the position reports ships and aircraft already broadcast.
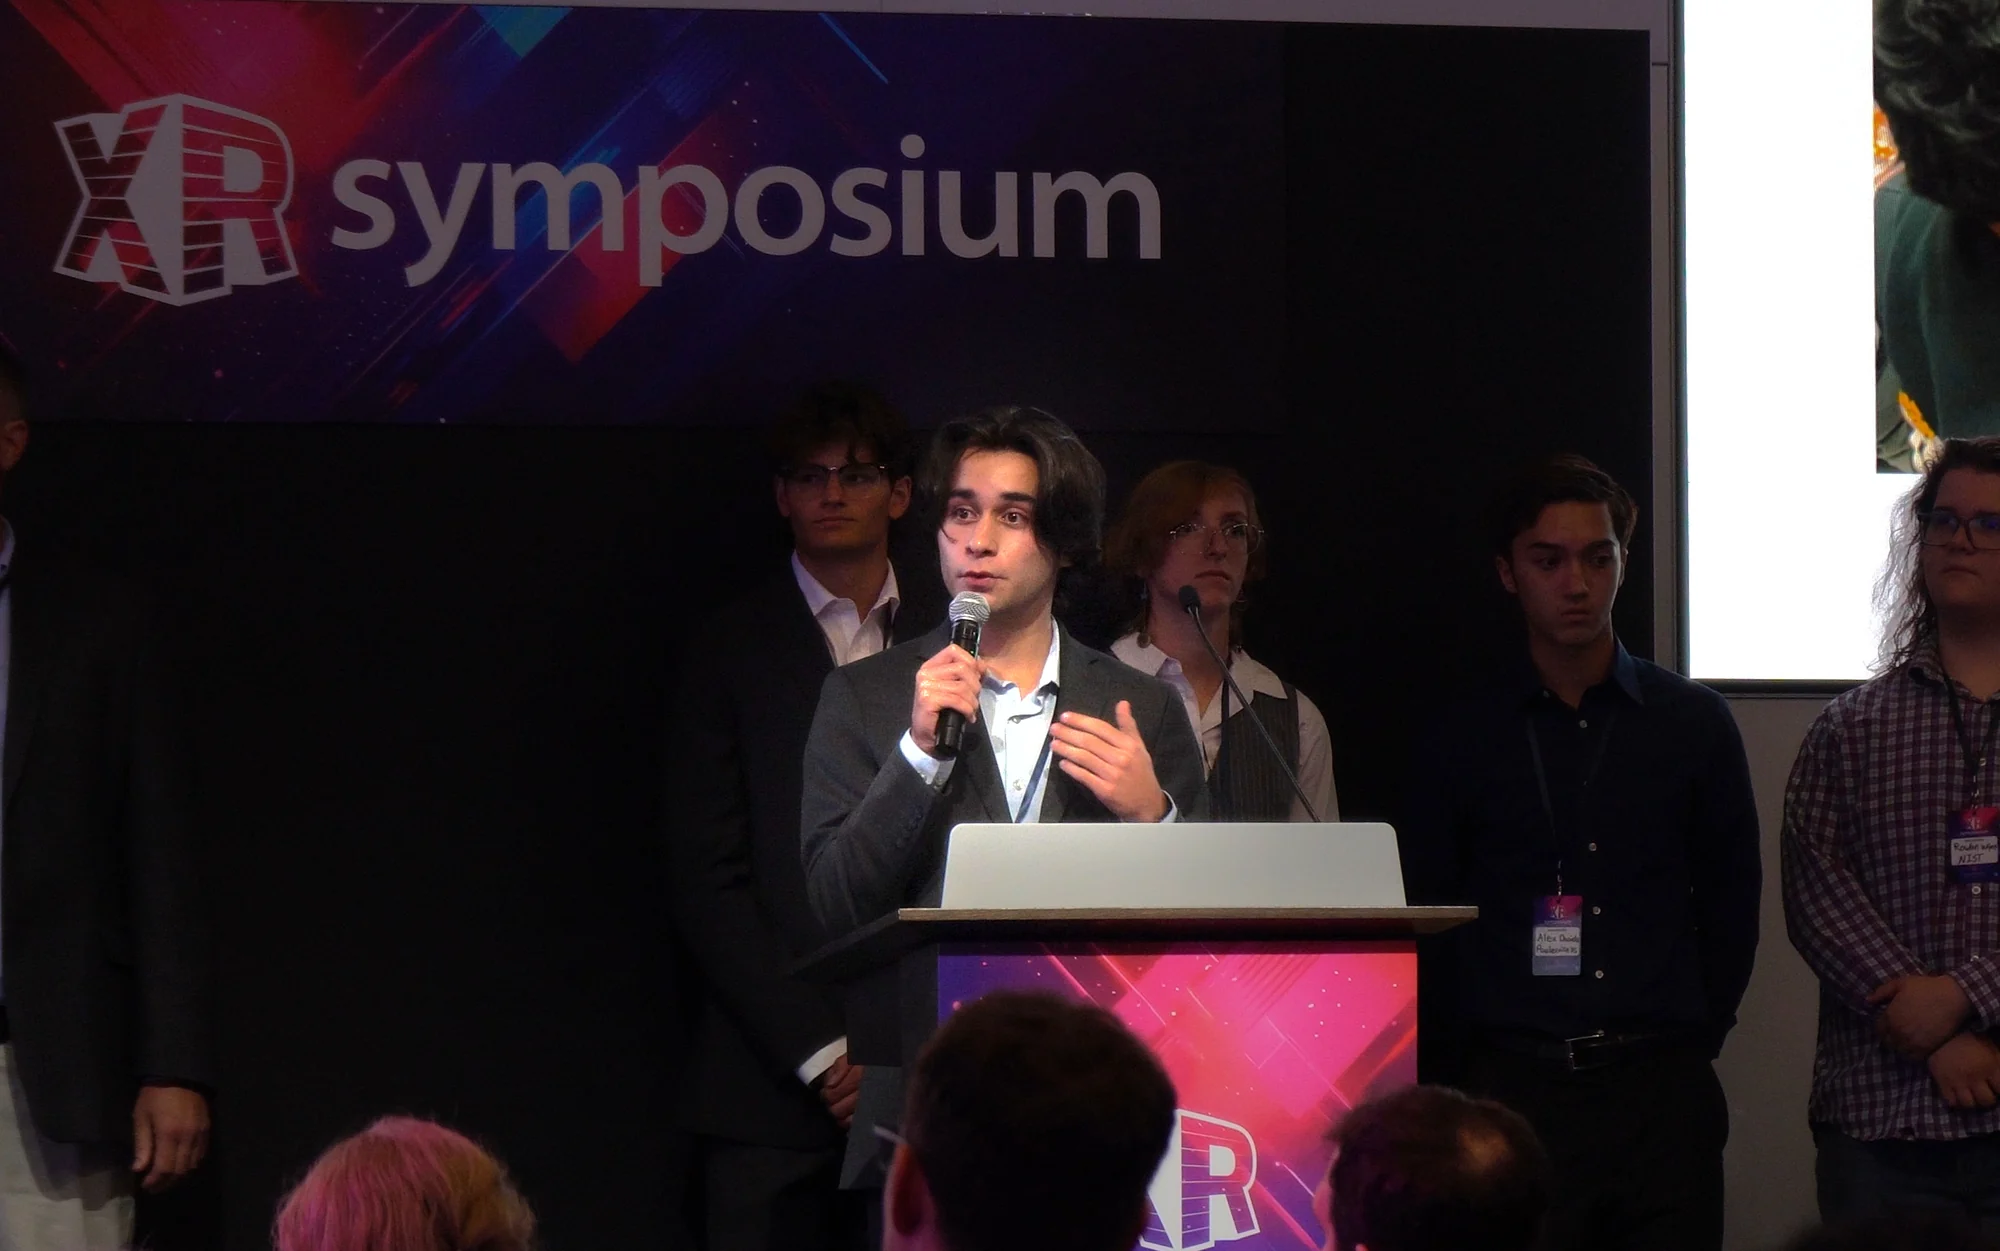
A rover mission on a simulated planet, turned into a digital twin you can walk through in VR. First high school students to speak at the Johns Hopkins APL XR Symposium.
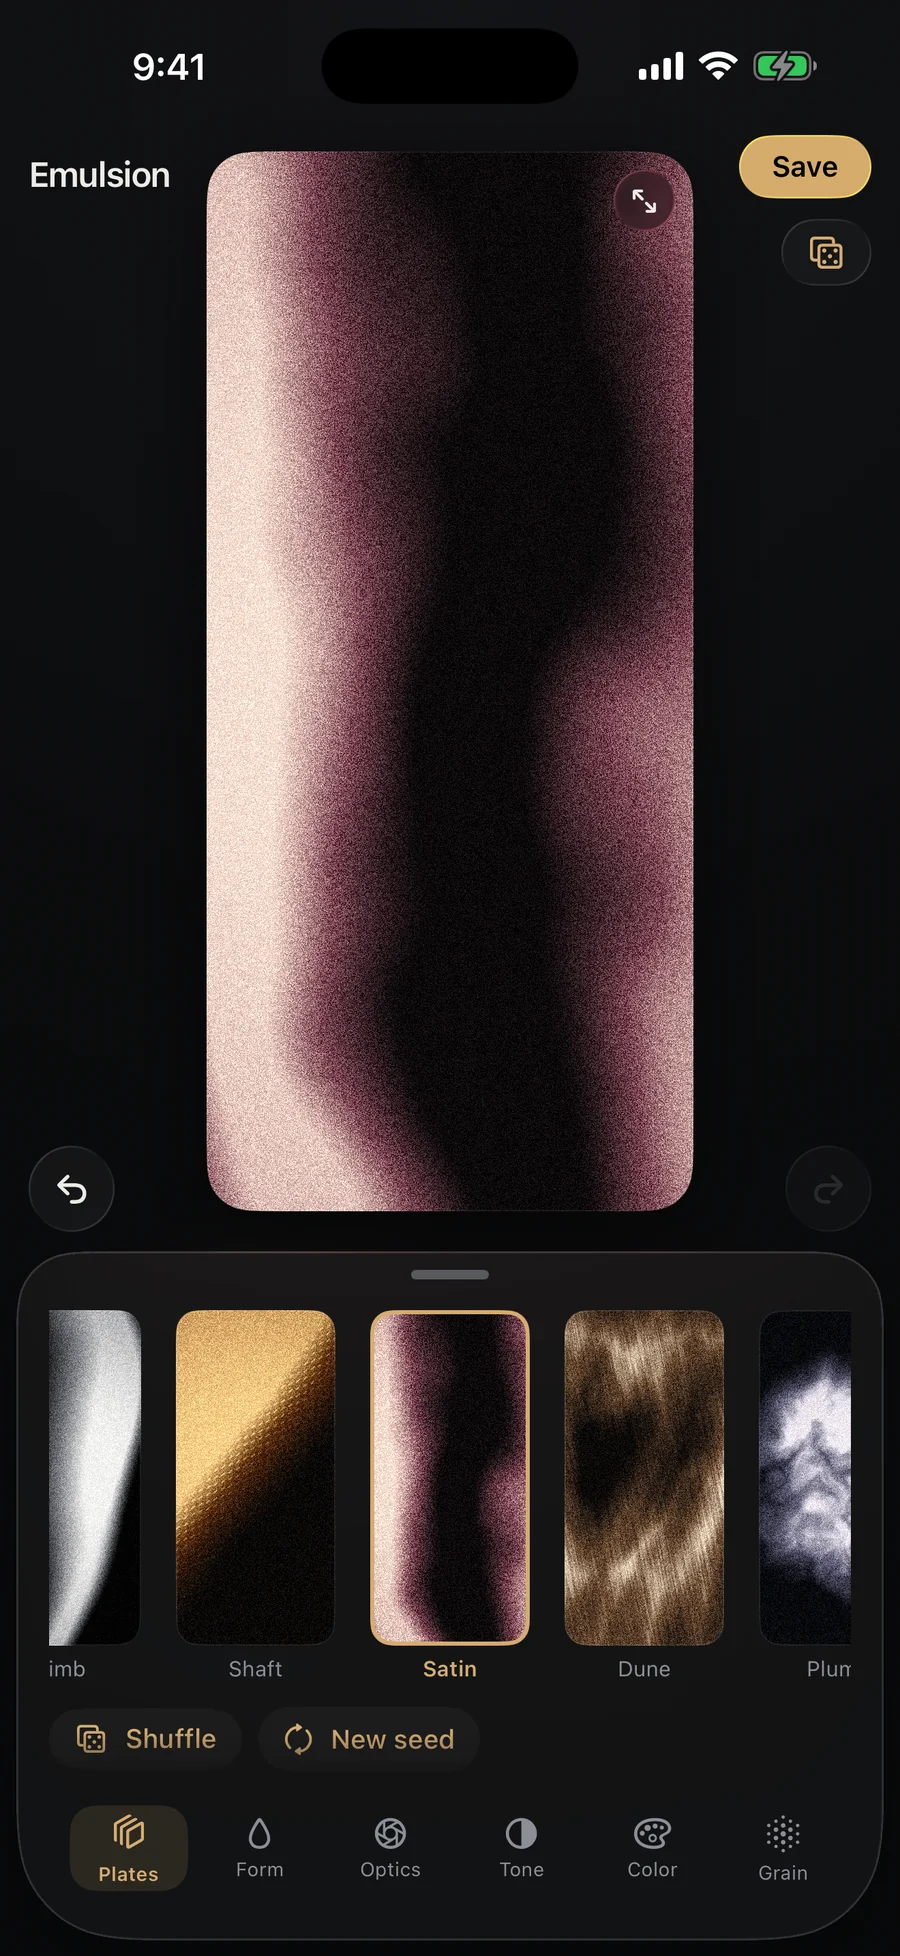
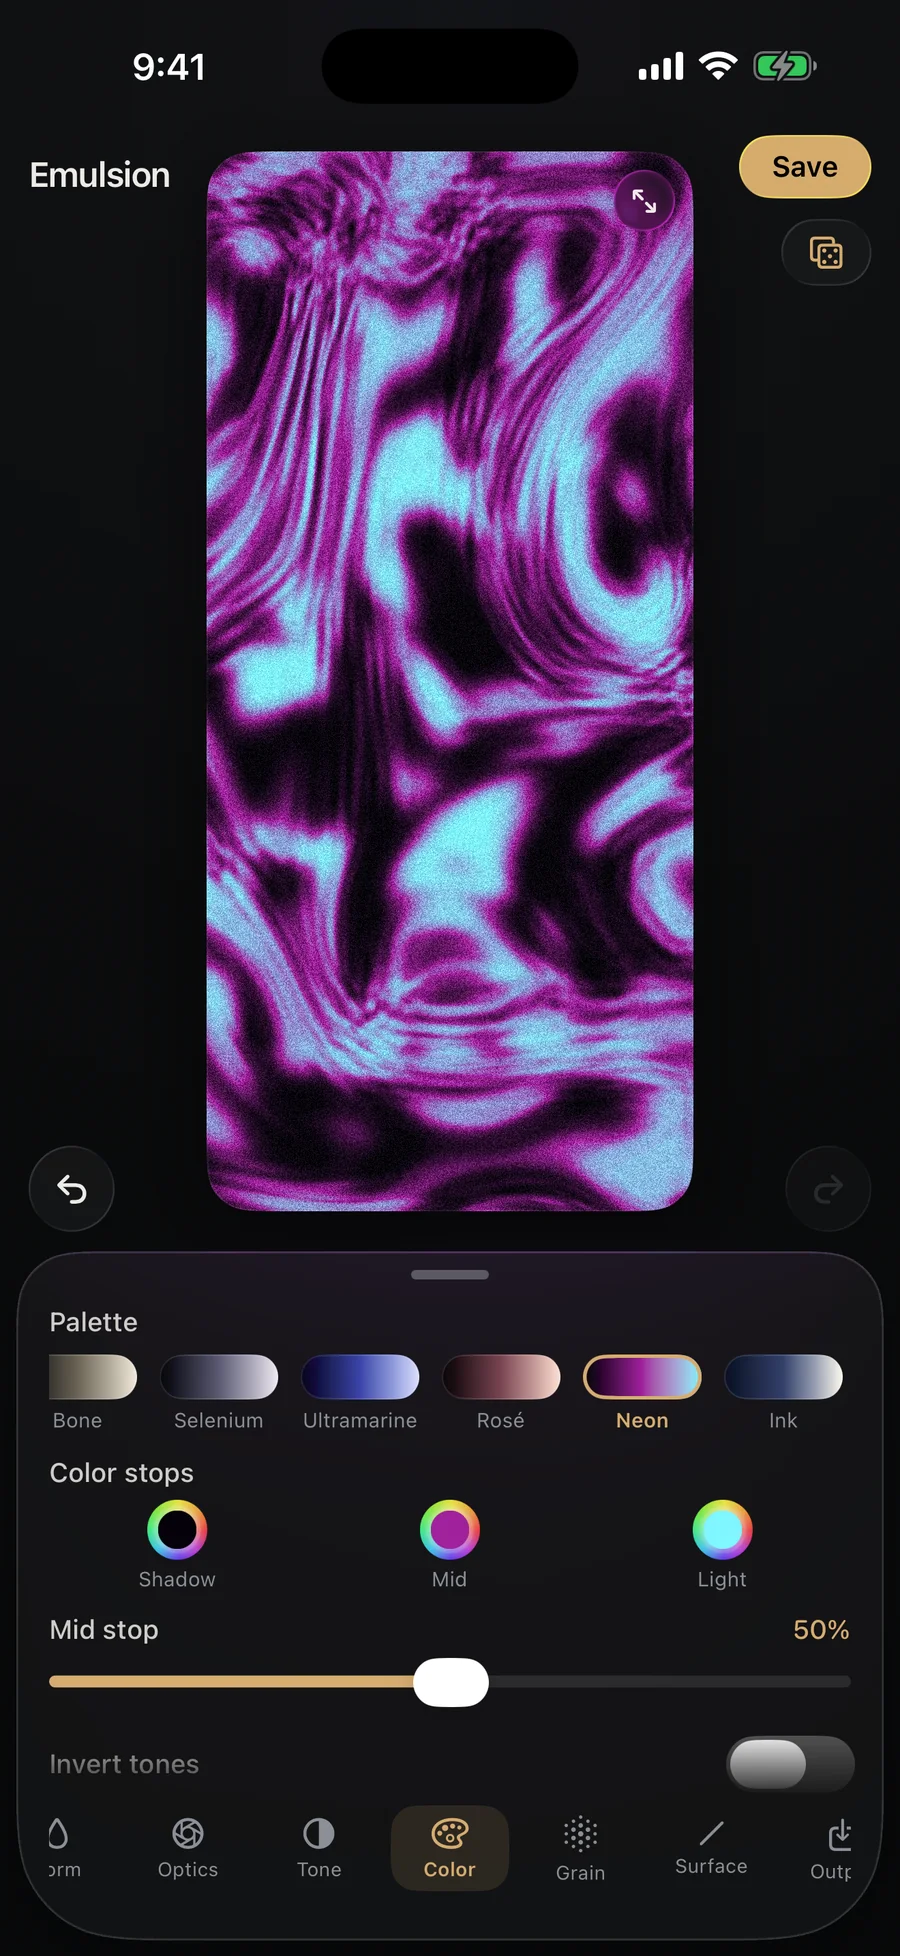
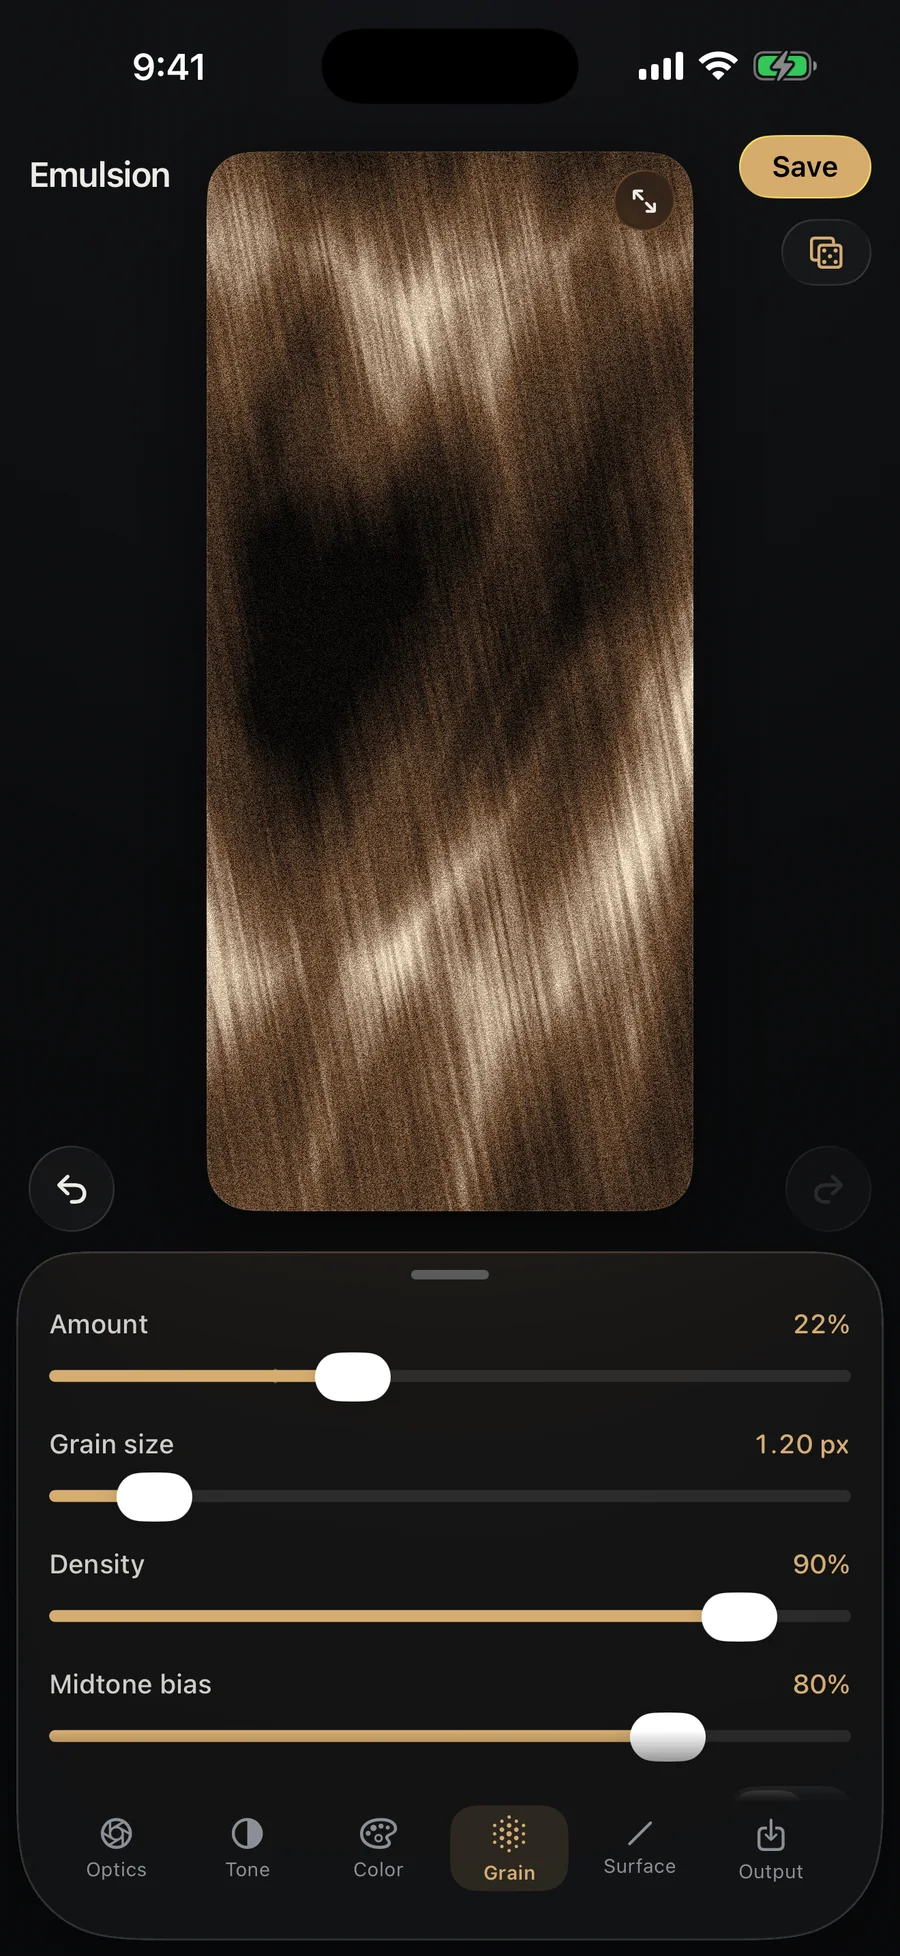
An iPhone app for making grainy, abstract wallpapers. Start with a plate, adjust the form, color and grain, and save it at the resolution of your screen. Every pixel is generated on your device.